May 2026 – Jul 2026
Robotics R&D Systems Intern · Kawasaki Robotics India
Worked on industrial robotics R&D with a focus on vision-based applications, system integration, and software development for robotic systems.
Mechatronics · Robotics · Intelligent Systems
I build intelligent machines by connecting mechanics, control, perception and software.
Mechatronics & Automation engineer working across mechanical design, embedded systems, robotics, computer vision, and intelligent control. My focus is system integration — making individual technologies work together as reliable machines.
Experience
Robotics R&D Systems Intern
Kawasaki Robotics India · 2026
Leading
Mechanical & Design Head
Dreadnought Robotics · Present
Experience
Robotics R&D Systems Intern
Kawasaki Robotics India · 2026
Leading
Mechanical & Design Head
Dreadnought Robotics · Present
Skills
A full-stack mechatronics and robotics toolkit spanning mechanical design, control, robotics, perception, and intelligent systems.
How I Build
A practical loop for turning uncertain ideas into tested engineering systems.
Define the system, constraints, and the real problem.
Understand the science, tools, and prior work before building.
Turn the model into hardware, software, or a working prototype.
Test against reality, find failure modes, and refine the system.
Integrate what works into a more capable and reliable system.
System Profile
I work across the physical and computational layers of intelligent robotic systems — from mechanisms and embedded hardware to control, perception, and robot intelligence.
Integrating disciplines for innovative solutions
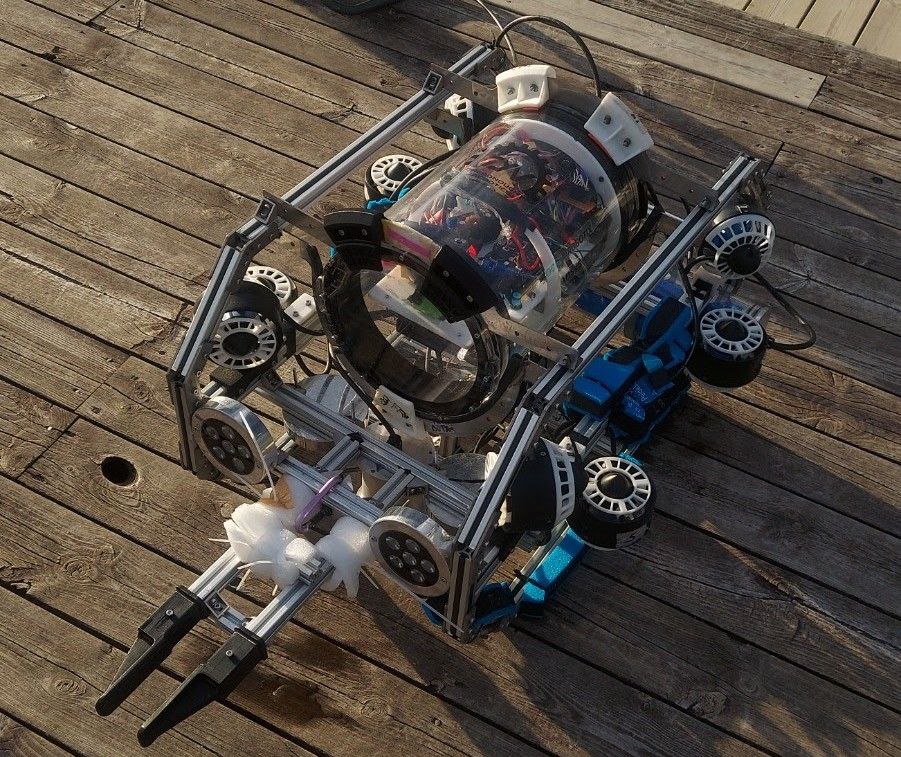
Designed a modular AUV including hull CAD, propulsion layout, and system-level control architecture. Performed hydrodynamic CFD analysis and defined a ROS 2–based simulation roadmap for validating navigation and stability prior to prototyping.
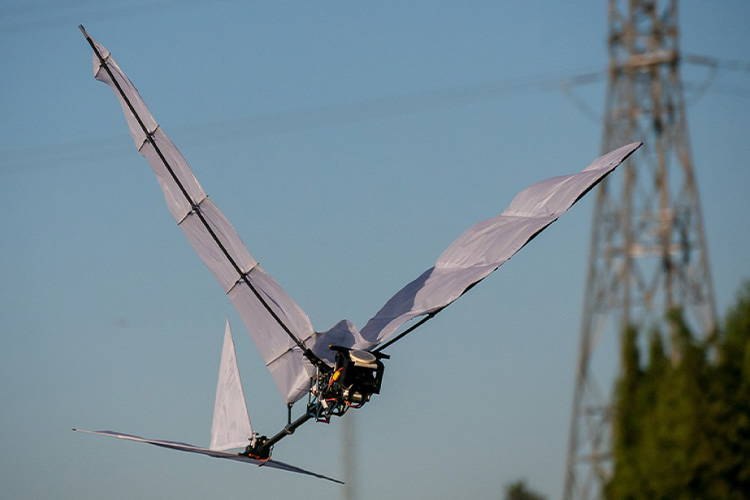
Designed a biomimetic flapping-wing ornithopter for silent wildlife surveillance, focusing on mechanism design, kinematic analysis, and overall system integration. Project paused at design stage pending prototype resources.
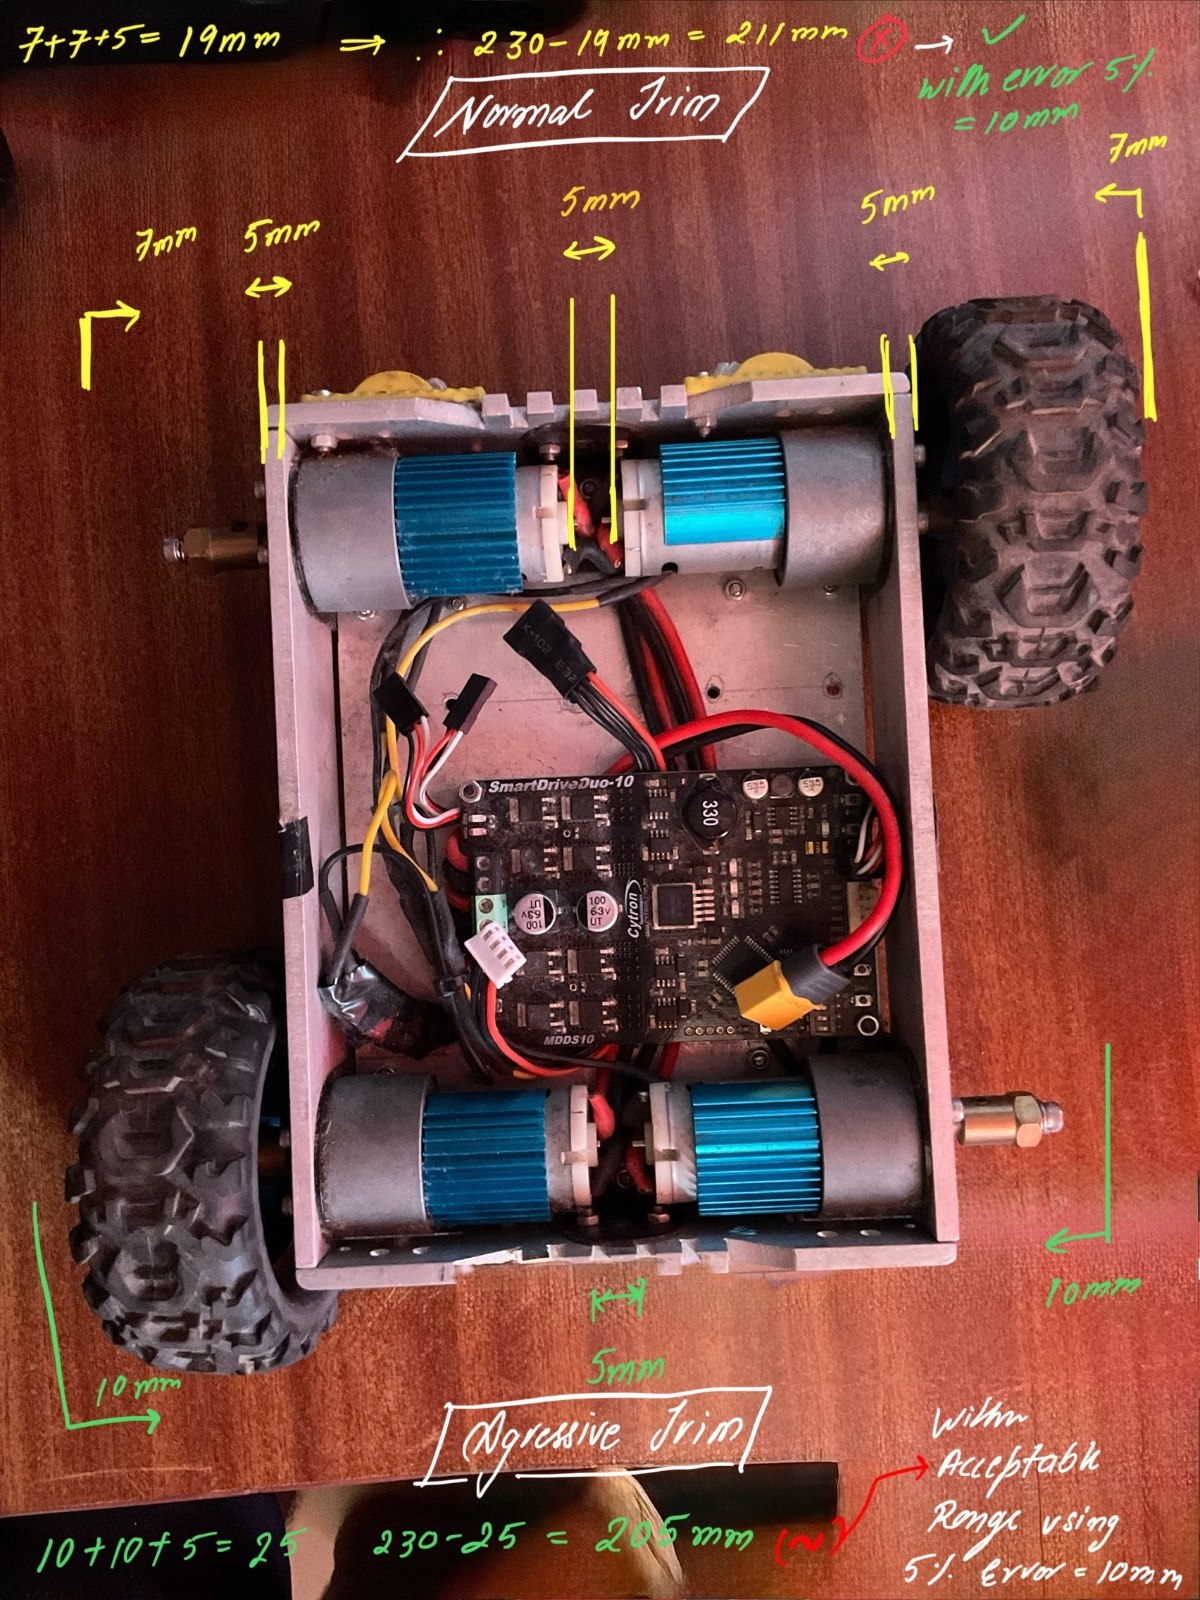
Built and deployed a competitive robotics system for a national-level techfest. Contributed to mechanical design, system integration, and control implementation under strict competition constraints.
Professional Journey
From hands-on mechanical design to robotics R&D, each stage has expanded the systems I can design, integrate, and build.
Worked on industrial robotics R&D with a focus on vision-based applications, system integration, and software development for robotic systems.
Leading mechanical architecture and system integration for an autonomous underwater vehicle, coordinating design decisions across the team's multidisciplinary development.
Led mechanical subsystem development for the AUV, contributing to design, fabrication, testing, and integration of the vehicle.
Built practical experience in mechanical design, fabrication, and subsystem development while contributing to the team's underwater robotics platform.
Managed budgeting, finances, and fundraising while supporting the execution of student-led community initiatives.
Research
Research at the intersection of intelligent systems, robotics, and emerging technologies.
Results in Engineering
A research-driven mobile decision support system integrating augmented reality, intelligent crop recommendation, and yield estimation to support data-driven agricultural decision making.
Intellectual Property
Translating engineering ideas into protectable innovations.
Patent work focused on the development of an innovative engineering system and its application in intelligent robotic systems.
Milestones
Milestones across international robotics, engineering, innovation, and technical competitions.
2026
Sanya, China
Qualified for the Singapore AUV Challenge (SAUVC) as part of Dreadnought Robotics with an autonomous underwater vehicle.
2026
IEEE Oceanic Engineering Conference — Sanya, China
Received the Innovation Award for Dreadnought Robotics' underwater robotics work and innovative engineering approach.
2026
Stavanger, Norway
Qualified for the international autonomous systems competition as part of Dreadnought Robotics.
2025
National Technical Competition
Participated in national-level technical and robotics challenges, contributing to rapid prototyping, mechanical design, and system integration.
2025
National Innovation Challenge
Participated in the national-level innovation challenge, contributing to technical problem-solving and prototype development.
Field Notes
Ideas, reflections, and technical explorations across robotics, AI, and intelligent systems.
Building something in robotics, intelligent systems, automation, or mechatronics? I am always open to thoughtful technical conversations and meaningful collaborations.
I aim to respond within 24–48 hours. For technical or collaboration requests, a little context about the problem is always helpful.